 |
| August 12, 2025 | Volume 21 Issue 30 |
Motion Control News & Products
Designfax weekly eMagazine
Archives
Partners
Manufacturing Center
Product Spotlight
Modern Applications News
Metalworking Ideas For
Today's Job Shops
Tooling and Production
Strategies for large
metalworking plants
Simplify pick and place with the THK PPR
 THK's Pick-and-Place Robot PPR is a robot that can pick up delicate or minute workpieces such as electronic components and quickly and accurately transfer and assemble them to the base. In addition to the basic movements of raising, lowering, and rotating, various sensors (such as a force sensor), solenoid valves, and controller are all in one unit. The PPR is a process-optimized robot that can improve the production speed of the parts assembly processes and reduce work damage.
Learn more.
New ROBOMACHINE products and more from FANUC
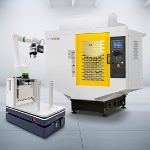 FANUC America demonstrated the future of manufacturing at IMTS 2026 last week, showcasing how Physical AI-powered automation integrates advanced CNC, machining, and robotics to boost productivity and speed deployment. One highlight was the debut of the ROBODRILL DC Series machining centers -- including the high-speed D54CS and D74CS models -- alongside interactive demonstrations featuring collaborative robots, robotic welding, material joining, painting, and assembly technology.
See all the FANUC new tech featured at IMTS.
What is a stick-slip bi-phase positioning stage?
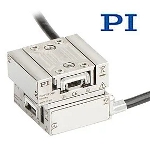 PI (Physik Instrumente) is expanding its Bi-Phase Inertia Drive (BIX) technology with new motor architectures for compact, high-precision nanopositioning applications. Based on the piezo stick-slip principle, BIX stages replace conventional single actuators with two synchronized multilayer piezo actuators. This compact design delivers precise, repeatable motion while maintaining piezo inertia self-locking.
Learn more about this technology.
Universal Robots unveils Gen 7 robot platform!
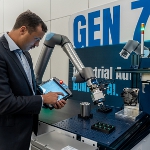 Redesigned from controller to tool flange, the new Gen 7 robot platform is out-of-the-box AI-ready, giving companies the modern software tools and next-level connectivity they need to confidently take AI from the lab into industrial operations. Gen 7 represents a unified system upgrade designed to make even the most demanding tasks and setups easier. See all the new features -- they are significant.
Read the full article.
Adaptor mount and hub options provide flexibility
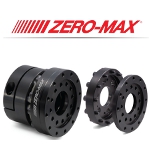 Zero-Max's new CD Power-Series Flexible Shaft Couplings feature ISO Flange Adaptors matching ISO 9409-1 patterns on gear reducers and robotics. Eliminating custom transitions, this direct connection enhances torsional stiffness and positioning accuracy while saving space, weight, and inertia. Offering continuous torque up to 65,000 in.-lb and versatile hub options, these compact couplings deliver high power density.
Learn more.
Top-shelf motors: Completely revised maxon catalog
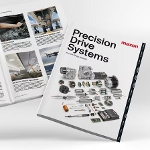 maxon has completely overhauled its 2026/2027 catalog, streamlining its portfolio to reduce complexity and improve navigation. The new structure features dedicated sections for business units -- Medical, Aerospace, Industrial Automation, Mobility -- and specialized fields like Robotics and Space. Key product highlights include new ECX PRIME and ECX FLAT motors, GSW planetary gearheads, and ESCON2/EPOS4 controllers.
Learn more and check it out.
Custom stators, rotors, and motor assemblies for low- to mid-volume applications
 Arnold's Ramco Electric Motors is your single partner for custom motor components and complete assemblies. Ramco builds solutions for AC induction, switched reluctance, and brushless DC designs up to 200+ HP. Capabilities include custom stators, rotor-shaft assemblies, aluminum and copper casting, induction brazing, permanent magnet assembly, and precision rotor balancing.
Learn more.
Rotate robot arms more than 600 degrees
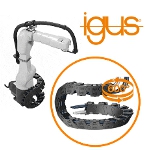 The unsupported twisterchain® from igus eliminates the need for additional trough systems or guide plates in robotic applications, especially in palletizing. This results in a clean, efficient, and space-saving system architecture that delivers both technical and economic advantages. Thanks to its specialized design, it supports rotations of over 600 degrees.
Learn more.
Match the torque of rotary solenoids to your application
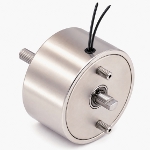 Magnetic Sensor Systems has launched the Made in USA R-10-200-CWM Series of clockwise rotary solenoids. Measuring 2.00 in. in diameter and 1.04 in. long with 18 different AWG options and a serrated front shaft end, these compact units optimize torque, current, and duty cycle. When power is removed, an integral return spring automatically returns the shaft to its home position. The shaft is supported by two high-precision radial ball bearings, providing smooth operation with no axial play. Applications include medical, security, and office equipment.
Learn more.
Planetary servo gear unit: New economy series
SEW-EURODRIVE has expanded its PxG planetary servo gear unit portfolio with the new PxG economy series, introducing the P1.G, P2.G, and P3.G performance classes. Designed for standard industrial automation applications like packaging and material handling, these cost-effective units feature peak torque ratings from 11 to 500 Nm and over 20,000 hours of service life, helping machine builders eliminate unnecessary over-specification.
Learn more.
Compact hexapod 6-DOF alignment system has overload protection
PI's compact H-811.I2HS hexapod delivers precise 6-DOF motion with patented overload protection, simplifying setup and operation in OEM applications. This built-in protection safeguards precision mechanics during installation and integration against accidental forces or improper handling. Furthermore, the hexapod mounts in any orientation, granting system designers exceptional flexibility for optical, photonics, microscopy, metrology, and automation systems.
Learn more.
What is STUDROLLER technology? Cross Roller Guides
NB SLIDE WAY cross roller guides use precision rollers to provide stable, non-recirculating linear motions in precision stages, inspection equipment, semiconductor manufacturing, and more. At the heart of all NB cross roller bearings is the STUDROLLER mechanism, which eliminates the cage-creep phenomenon that, over time, can create deviances in cross roller retainer performance. NB cross roller guides equipped with this system are more accurate and better performing than any other comparable products on the market today. High acceleration and faster cycle times are possible in any orientation.
View the video.
Ruggedized Nano servo drives for harsh environs
Copley Controls has released its R47 and R48 NanoPlus Micro Module servo drives. Designed for extreme environments and space-constrained applications, these rugged platforms operate from 9 to 180 VDC, delivering peak power up to 6.3 kW. Offering CANopen (R47) or EtherCAT (R48) communications, both feature STO SIL 3 safety and broad encoder support. Well suited for COTS military, nautical, aviation, oil refining, and vehicle-based systems.
Learn more.
Simplify AC motor control with the new OMRON M1 Inverter
The OMRON M1 Inverter simplifies machine design by unifying motion, safety, networking, and motor control into a single platform. Available in M1-STD, M1-ECT, and M1-EMP models, it controls IM and PM motors with high precision. Featuring SIL3 PLe STO safety and native EtherCAT, EtherNet/IP, or RS-485 communications, the M1 accelerates development within the Sysmac environment.
Learn more.
Flexible planetary gearheads: Quiet, extremely robust
FAULHABER GPT gearheads for miniature and micro motors deliver high power density, exceptional flexibility, and excellent cost efficiency. Designed for seamless integration with diverse motors and encoders, these compact planetary drives feature hardened stainless steel components that reliably withstand extreme torques and abrupt load changes. Offered in standard, low-noise, and high-torque variants, they ensure precise, durable performance across wide operating temperature ranges.
Learn more.
Weird science: New vision-based system teaches machines to understand their bodies
By Rachel Gordon, MIT
In an office at MIT's Computer Science and Artificial Intelligence Laboratory (CSAIL), a soft robotic hand carefully curls its fingers to grasp a small object. The intriguing part isn't the mechanical design or embedded sensors -- in fact, the hand contains none. Instead, the entire system relies on a single camera that watches the robot's movements and uses that visual data to control it.
This capability comes from a new system CSAIL scientists developed, offering a different perspective on robotic control. Rather than using hand-designed models or complex sensor arrays, it allows robots to learn how their bodies respond to control commands, solely through vision. The approach, called Neural Jacobian Fields (NJF), gives robots a kind of bodily self-awareness. An open-access paper about the work was published in Nature on June 25, 2025.
"This work points to a shift from programming robots to teaching robots," says Sizhe Lester Li, MIT PhD student in electrical engineering and computer science, CSAIL affiliate, and lead researcher on the work. "Today, many robotics tasks require extensive engineering and coding. In the future, we envision showing a robot what to do and letting it learn how to achieve the goal autonomously."
The motivation stems from a simple but powerful reframing: The main barrier to affordable, flexible robotics isn't hardware -- it's control of capability, which could be achieved in multiple ways. Traditional robots are built to be rigid and sensor-rich, making it easier to construct a digital twin, a precise mathematical replica used for control. However, when a robot is soft, deformable, or irregularly shaped, those assumptions fall apart. Rather than forcing robots to match our models, NJF flips the script; it gives robots the ability to learn their own internal model from observation.
Look and learn
This decoupling of modeling and hardware design could significantly expand the design space for robotics. In soft and bio-inspired robots, designers often embed sensors or reinforce parts of the structure just to make modeling feasible. NJF lifts that constraint. The system doesn't need onboard sensors or design tweaks to make control possible. Designers are freer to explore unconventional, unconstrained morphologies without worrying about whether they'll be able to model or control them later.
"Think about how you learn to control your fingers: you wiggle, you observe, you adapt," says Li. "That's what our system does. It experiments with random actions and figures out which controls move which parts of the robot."
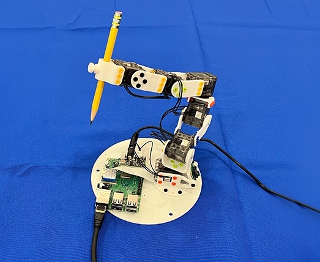
This 3D-printed robotic arm holds a pencil as it trains using random movements and a single camera -- part of a new control system called Neural Jacobian Fields (NJF). Rather than relying on sensors or hand-coded models, NJF allows robots to learn how their bodies move in response to motor commands purely from visual observation, offering a pathway to more flexible, affordable, and self-aware robots. [Credit: Image courtesy of the researchers/MIT]
The system has proven robust across a range of robot types. The team tested NJF on a pneumatic soft robotic hand capable of pinching and grasping, a rigid Allegro hand, a 3D-printed robotic arm, and even a rotating platform with no embedded sensors. In every case, the system learned both the robot's shape and how it responded to control signals -- just from vision and random motion.
The researchers see potential far beyond the lab. Robots equipped with NJF could one day perform agricultural tasks with centimeter-level localization accuracy, operate on construction sites without elaborate sensor arrays, or navigate dynamic environments where traditional methods break down.
At the core of NJF is a neural network that captures two intertwined aspects of a robot's embodiment: its three-dimensional geometry and its sensitivity to control inputs. The system builds on neural radiance fields (NeRF), a technique that reconstructs 3D scenes from images by mapping spatial coordinates to color and density values. NJF extends this approach by learning not only the robot's shape, but also a Jacobian field, a function that predicts how any point on the robot's body moves in response to motor commands.
To train the model, the robot performs random motions while multiple cameras record the outcomes. No human supervision or prior knowledge of the robot's structure is required -- the system simply infers the relationship between control signals and motion by watching.
Once training is complete, the robot only needs a single monocular camera for real-time, closed-loop control, running at about 12 Hertz. This allows it to continuously observe itself, plan, and act responsively. That speed makes NJF more viable than many physics-based simulators for soft robots, which are often too computationally intensive for real-time use.
In early simulations, even simple 2D fingers and sliders were able to learn this mapping using just a few examples. By modeling how specific points deform or shift in response to action, NJF builds a dense map of controllability. That internal model allows it to generalize motion across the robot's body, even when the data are noisy or incomplete.
"What's really interesting is that the system figures out on its own which motors control which parts of the robot," says Li. "This isn't programmed -- it emerges naturally through learning, much like a person discovering the buttons on a new device."
Published August 2025
Rate this article
View our terms of use and privacy policy