 |
| September 16, 2025 | Volume 21 Issue 35 |
Designfax weekly eMagazine
Archives
Partners
Manufacturing Center
Product Spotlight
Modern Applications News
Metalworking Ideas For
Today's Job Shops
Tooling and Production
Strategies for large
metalworking plants
Can a big ball robot take on the Moon?
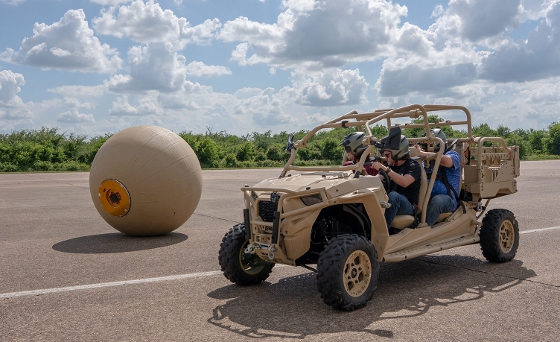
Texas A&M RAD Lab researchers ride along with RoboBall III, a 6-ft diameter rolling Moon robot prototype, during a test run. [Credit: Image by Emily Oswald/Texas A&M Engineering]
By Alyssa Schaechinger, Texas A&M University College of Engineering
While working at NASA in 2003, Dr. Robert Ambrose, now director of the Robotics and Automation Design Lab (RAD Lab), designed a robot with no fixed top or bottom. Being a sphere, the RoboBall could not flip over, and its shape promised access to places wheeled or legged machines could not reach -- from the deepest lunar crater to the uneven sands of a beach. Two of his students built the first prototype, but then Ambrose shelved the idea to focus on drivable rovers for astronauts.
When Ambrose arrived at Texas A&M University in 2021, he saw a chance to reignite his idea. With funding from the Chancellor's Research Initiative and Governor's University Research Initiative, Ambrose brought RoboBall back to life.
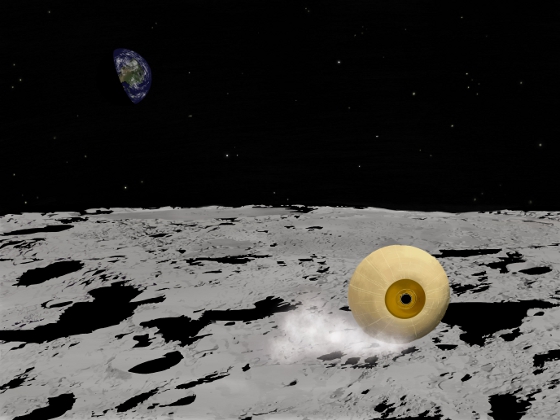
Artist's concept of a RoboBall on the Moon. Inside the robot is a two-degree-of-freedom pendulum that shifts the robot's center of gravity to create motion. [Credit: Image by Kaitlyn Johnson/Texas A&M Engineering]
Now, two decades after the original idea, RoboBall is rolling across the grounds of Texas A&M University.
Driven by graduate students Rishi Jangale and Derek Pravecek, the RAD Lab is intent on sending RoboBall, a novel spherical robot, into uncharted terrain.
Jangale and Pravecek, both Ph.D. students in the J. Mike Walker '66 Department of Mechanical Engineering, have played a significant part in getting the ball rolling once again.
"Dr. Ambrose has given us such a cool opportunity. He gives us the chance to work on RoboBall however we want," said Jangale, who began work on RoboBall in 2022. "We manage ourselves, and we get to take RoboBall in any direction we want."
VIDEO: Keeping the RoboBall rolling. [Credit: Video by Logan Jinks/Texas A&M Engineering]
Pravecek echoed that sense of freedom. "We get to work as actual engineers doing engineering tasks. This research teaches us things beyond what we read in textbooks," he said. "It really is the best of both worlds."
At the heart of the project is the simple concept of a "robot in an airbag." Two versions now exist in tandem. RoboBall II, a 2-ft-diameter prototype, is tuned for trial runs, monitoring power output and control algorithms. RoboBall III has a diameter of 6 ft across and is built with plans to carry payloads such as sensors, cameras, or sampling tools for real-world missions.
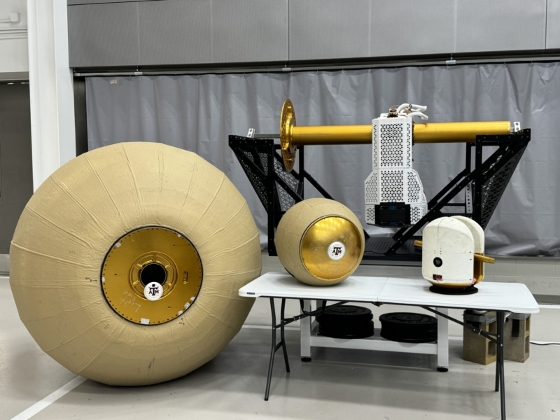
RoboBall family: (Left to right) RoboBall III shell, RoboBall II shell (rear), RoboBall III pendulum on test stand, RoboBall II pendulum. [Credit: Photo courtesy of Texas A&M Engineering]
Upcoming tests will continue to take RoboBall into outdoor environments. RAD Lab researchers are planning field trials on the beaches of Galveston to demonstrate a water-to-land transition, testing the robot's buoyancy and terrain adaptability in a real-world setting for applications here on Earth.
"Traditional vehicles stall or tip over in abrupt transitions," Jangale explained. "This robot can roll out of water onto sand without worrying about orientation. It's going where other robots can't."
The factors that create the versatility of RoboBall also lead to some of its challenges. Once sealed inside its protective shell, the robot can only be accessed electronically. Any mechanical failure means disassembly and digging through layers of wiring and actuators.
VIDEO: A look inside the smaller RoboBall II prototype -- see inside the unit. [Credit: Texas A&M Engineering]
"Diagnostics can be a headache," said Pravacek. "If a motor fails or a sensor disconnects, you can't just pop open a panel. You have to take apart the whole robot and rebuild. It's like open-heart surgery on a rolling ball."
RoboBall's novelty means the team often operates without a blueprint.
"Every task is new," Jangale said. "We're very much on our own. There's no literature on soft-shelled spherical robots of this size that roll themselves."
Despite those hurdles, the students find themselves surprised every time the robot outperforms expectations.
"When it does something we didn't think was possible, I'm always surprised," Pravecek said. "It still feels like magic."
The team set a new record when RoboBall II reached 20 mph, roughly half its theoretical power output. "We didn't anticipate hitting that speed so soon," Pravecek said. "It was thrilling, and it opened up new targets. Now we're pushing even further."
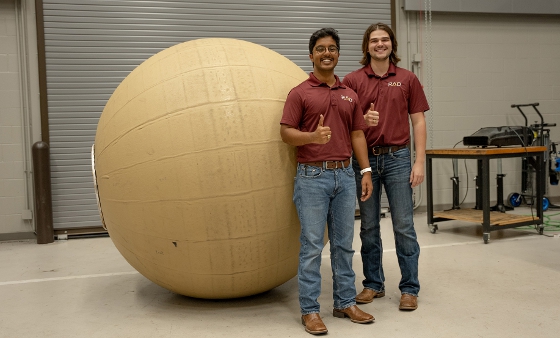
Rishi Jangale (left) and Derek Pravecek with RoboBall III. [Credit: Image by Emily Oswald/Texas A&M Engineering]
Ambrose sees these reactions as proof that student-led innovation thrives when engineers have room to explore.
"The autonomy Rishi and Derek have is exactly what a project like this needs," he said. "They're not just following instructions -- they're inventing the next generation of exploration tools."
Long-term goals include autonomous navigation and remote deployment. The team hopes to see RoboBall dispatched from a lunar lander to chart steep crater walls or launched from an unmanned drone to survey post-disaster landscapes on Earth. Each ball could map terrain, transmit data back to operators, and even deploy instruments in hard-to-reach spots.
VIDEO: Video compilation of RoboBall III prototype testing. [Credit: Texas A&M Engineering]
"Imagine a swarm of these balls deployed after a hurricane," Jangale said. "They could map flooded areas, find survivors, and bring back essential data -- all without risking human lives."
As the RoboBall project rolls on, student-driven research stands on full display.
"Engineering is problem solving at its purest," Ambrose said. "Give creative minds a challenge and the freedom to explore, and you'll see innovation roll into reality."
RoboBall III specs:
- Dimensions: 6 ft (1.83 m) in diameter
- Driving mechanism: Propelled by a 2-degrees-of-freedom internal pendulum on an axle. As the pendulum swings and shifts, it transfers momentum to the outer shell, causing it to roll and steer
- Outer shell: The inflatable pneumatic shell can be inflated or deflated to adapt its traction to different surfaces
- Payload: An internal payload bay can accommodate various tools, including sensors, cameras, and sampling equipment, up to 16U in size (1U is 10 cm x 10 cm x 10 cm)
- Speed: In tests, the robot has been able to travel at speeds up to 20 mph (32 km/h)
- Adaptability beyond lunar uses: A critical part of RoboBall III's functionality is its ability to operate in various terrains including climbing and descending slopes, operating on grass and gravel, and driving on water
Published September 2025
Rate this article
View our terms of use and privacy policy